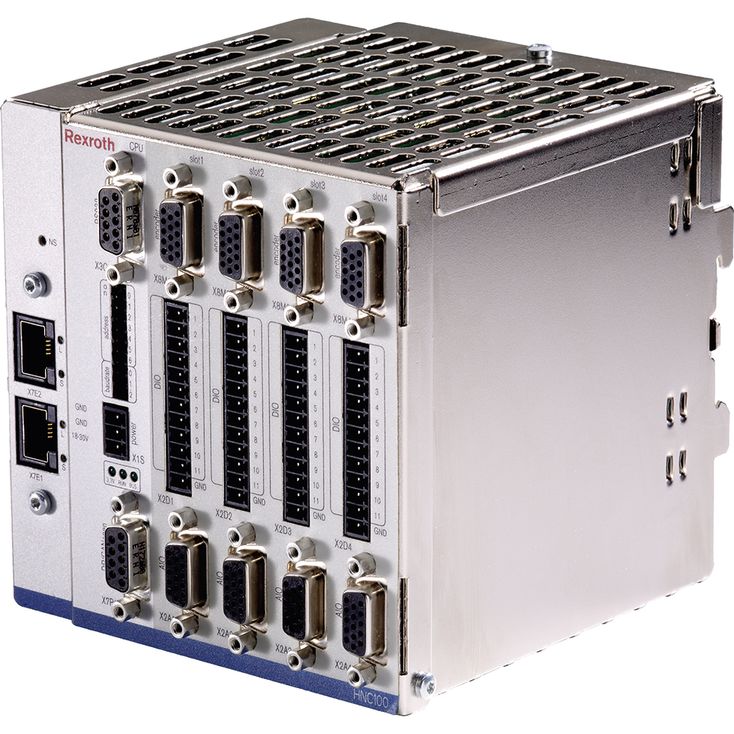
VT-HNC100-1-3X/C-I-00/000
Rexroth
R901215000
用于控制1至4根轴。
数控编程。
WinPed 7操作软件未获准用于Windows 10!
符合电磁兼容指令2004/108/EC的CE要求。
控制器功能可自由配置,包括位置、力、压力、位置/压力或位置/力切换、速度、按行程减速,以及主从式或平均值原理的同步控制。
总线连接:Sercos、PROFINET RT、EtherNet/IP。
实际值检测:支持增量式位置传感器、绝对式位置传感器(SSI),以及0至±10 V、0(4)至20 mA模拟信号。
操纵量输出可采用电压或电流。
维修接口为RS232,可选TCP/IP。
01 | 02 | 03 | 04 | 05 | 06 | 07 | ||||||
VT-HNC100 | – | – | 3X | / | – | – | / |
01 | VT-HNC100 | Serial unit |
02 | Version Compact for 1 axis | C |
Version for 1 hydraulic axis | 1 | |
Versions for 2 hydraulic axes | 2 | |
Versions for 3 hydraulic axes | 3 | |
Versions for 4 hydraulic axes | 4 | |
03 | Component series 30 ... 39 (30 ... 39: unchanged technical data and pin assignment) | 3X |
Bus connection 2) | ||
04 | PROFIBUS DP | P |
CANopen | C | |
PROFINET RT (not in connection with Compact version) | N | |
EtherNet/IP (not in connection with Compact version) | E | |
Position transducer | ||
05 | Incremental/SSI (not in connection with Compact version) | I |
SSI (only in connection with Compact version) | S | |
06 | no fitting | 00 |
TCP/IP 1) | E0 | |
Option | ||
07 | without synchronism | G00 |
Synchronism 2-axis version | G02 | |
Synchronism 3-axis version | G03 | |
Synchronism 4-axis version | G04 | |
| 1) Only specify "E0" if the Ethernet service interface is desired for "PROFIBUS DP" | |
| 2) Versions without bus connections are not available. |
Type / version | VT-HNC100-C-3X | VT-HNC100-1-3X | VT-HNC100-2-3X | VT-HNC100-3-3X | VT-HNC100-4-3X | |
Component series | 3X | |||||
Type / version | VT-HNC100-C-3X | VT-HNC100-1-3X | VT-HNC100-2-3X | VT-HNC100-3-3X | VT-HNC100-4-3X | ||
Operating voltage 1) | UB | 18 to 30 VDC, residual ripple < 1.5 V | |||||
Current consumption at 24 VDC | I | approx. 500 mA | 1 to 4 A (depending on the HNC variant and the also supplied components) | ||||
| 1) | If a 24 V encoder supply is implemented directly via the VT-HNC100...3X (supply voltage is looped in), the encoder specification has to be observed. |
Type / version | VT-HNC100-C-3X | |||
Voltage input (reference to AGND - Analog ground) | Channel number | 1 | ||
Input voltage | UE | max. +12 V to –12 V (+10 V to –10 V measurable) | ||
Input resistance | RE | 200 kΩ ± 5 % | ||
Resolution | 5 mV | |||
Non-linearity | % | < 0.2 | ||
Calibration tolerance, max. 1) | 40 mV (with factory settings) | |||
Current inputs | Channel number | 2 | ||
Input current | IE | 4 mA to 20 mA | ||
Input resistance | RE | 225 Ω at 20 °C (100 Ω measuring resistance) | ||
Leakage current | IV | 0.1 to 0.4 % (with 100 Ω between pin 2 or pin 3 (Cin1+ or Cin2+) and "AGND" | ||
Resolution | 5 μA | |||
Voltage supply for analog sensors via VT-HNC100-C-3X | UB at X2A, pin 7 (+24 Vsens) | |||
| 1) | If the factory settings are insufficient, the measurement technology can be calibrated on site via software in a system-specific way. |
Type / version | VT-HNC100-1-3X | VT-HNC100-2-3X | VT-HNC100-3-3X | VT-HNC100-4-3X | |||
Voltage inputs (differential inputs) | Channel number | 2 | |||||
Input voltage | UE | max. +12 V to –12 V (+10 V to –10 V measurable) | |||||
Input resistance | RE | 200 kΩ ± 5 % | |||||
Resolution | 5 mV | ||||||
Non-linearity | % | < 0.2 | |||||
Calibration tolerance, max. 1) | 40 mV (with factory settings) | ||||||
Current inputs | Channel number | 2 | |||||
Input current | IE | 4 mA to 20 mA | |||||
Input resistance | RE | 350 Ω at 20 °C (100 Ω measuring resistance) | |||||
Leakage current | IV | 0.1 to 0.4 % | |||||
Resolution | 5 μA | ||||||
Voltage supply for analog sensors via VT-HNC100…3X | U | UB at X2A1 to X2A4, pin 14 (+24 Vsens) | |||||
| 1) | If the factory settings are insufficient, the measurement technology can be calibrated on site via software in a system-specific way. |
Type / version | VT-HNC100-C-3X | VT-HNC100-1-3X | VT-HNC100-2-3X | VT-HNC100-3-3X | VT-HNC100-4-3X | ||
Switching inputs (DI) | Number | 4 | 11 | ||||
Logic level | log 0 (low) ≤ 5 V; log 1 (high) ≥ 10 V to UB, Ie = 20 mA at UB = 24 V | ||||||
Connection | flexible conductor up to 1.5 mm2 | ||||||
Reference potential for all signals | DGND | ||||||
Type / version | VT-HNC100-C-3X | |||
Voltage outputs | Channel number | 2 | ||
Output voltage, normalized | Unorm | –10 V to +10 V (max. –10.7 V to +10.7 V) | ||
Output current, max. | Imax | ± 10 mA | ||
Load, min. | Rmin | kΩ | 1 | |
Resolution | 1.25 mV | |||
Non-linearity | in the range –9.5 V to +9.5 V | % | < 0.1 | |
in the range –10 V to –9.5 V and +9.5 V to +10 V | % | < 0.2 | ||
Type / version | VT-HNC100-1-3X | VT-HNC100-2-3X | VT-HNC100-3-3X | VT-HNC100-4-3X | |||
Analog outputs (AO: 1) per axis electronics 1) | 2 | ||||||
Non-linearity | in the range –9.5 V to +9.5 V | % | < 0.1 | ||||
in the range –10 V to –9.5 V and +9.5 V to +10 V | % | < 0.2 | |||||
Voltage output | Output voltage, normalized | Unorm | –10 V to +10 V (max. –10.7 V to +10.7 V) | ||||
Output current, max. | Imax | ± 10 mA | |||||
Load, min. | Rmin | kΩ | 1 | ||||
Residual ripple | ±60 mV (without noise) | ||||||
Resolution | 1.25 mV | ||||||
Current output | Output current, normalized | Inorm | 4 mA to 20 mA | ||||
Load, max. | Rmax | Ω | 500 | ||||
Resolution | 0.625 μA | ||||||
| 1) | Configurable as current or voltage output. Axis electronics slot 1 and axis electronics slot 2 feature two voltage outputs Vout1 and Vout2. Axis electronics slot 3 and axis electronics slot 4 feature one voltage output Vout1. |
Type / version | VT-HNC100-C-3X | VT-HNC100-1-3X | VT-HNC100-2-3X | VT-HNC100-3-3X | VT-HNC100-4-3X | ||
Switching outputs (DO) | Number | 2 | 11 | ||||
Logic level | log 0 (low) ≤ 2 V; log 1 (high) ≤ UB; Imax = 20 mA, maximum load capacity C = 0.047 μF | ||||||
Connection | flexible conductor up to 1.5 mm2 | ||||||
Reference potential for all signals | DGND | ||||||
Type / version | VT-HNC100-C-3X | |||
SSI transducer 1) | Coding | Gray code | ||
Data width | adjustable up to max. 28 bit | |||
Line receiver/driver | RS485 | |||
Voltage supply via VT-HNC100-C-3X | U | UB | ||
Reference potential for all signals | EGND | |||
| 1) | Due to the higher control quality, an SSI transducer with clock synchronization should be used |
Type / version | VT-HNC100-1-3X | VT-HNC100-2-3X | VT-HNC100-3-3X | VT-HNC100-4-3X | ||||
Incremental transducer with TTL output | Input voltage | log 0 | 0 to 1 V | |||||
log 1 | 2.8 to 5.5 V | |||||||
Input current | log 0 | -0.8 mA (with 0 V) | ||||||
log 1 | 0.8 mA (with 5 V) | |||||||
Frequency, max. related to Ua1 | fmax | kHz | 250 | |||||
Voltage supply for incremental transducers via VT-HNC100…3X | U | 5.25 V ±1 %, max. 400 mA total current over all axes at X8M1 to X8M4, Pin 12 (+5 Venc) | ||||||
SSI transducer 1) | Coding | Gray code | ||||||
Data width | adjustable up to max. 28 bit | |||||||
Line receiver/driver | RS485 | |||||||
Voltage supply for SSI transducers via VT-HNC100…3X | U | UB at X8M1 to X8M4, pin 14 (+24 Venc) | ||||||
Reference potential for all signals | EGND | |||||||
| 1) | Due to the higher control quality, an SSI transducer with clock synchronization should be used |
Type / version | VT-HNC100-C-3X | VT-HNC100-1-3X | VT-HNC100-2-3X | VT-HNC100-3-3X | VT-HNC100-4-3X | ||
Processor | 32 bit power PC | ||||||
Interface for WIN-PED 6, WIN-PED7 | RS232 | ||||||
Bus interface | PROFIBUS DP (max. 12 MBaud acc. to IEC 61158), CANopen | RS232, optional TCP/IP | |||||
| PROFIBUS DP (max. 12 MBaud acc. to IEC 61158), CANopen, PROFINET RT, EtherNet/IP | |||||||
Installation | Top hat rail TH 35-7.5 or TH 35-15 according to EN 60715 | ||||||
Admissible operating temperature range | ϑ | °C | 0 … +50 | ||||
Storage temperature range | ϑ | °C | -20 … +70 | ||||
Protection class according to EN 60529:1991 | IP 20 | ||||||
Weight | m | g | 440 | 585 | 690 | 850 | 960 |
m | 223 g 1) | ||||||
CE conformity | See features | ||||||
| 1) | with Ethernet, in addition |
Type / version | VT-HNC100-1-3X | VT-HNC100-2-3X | VT-HNC100-3-3X | VT-HNC100-4-3X | |
Minimum cycle time | ms | 2 | |||
Size of the cyclic I/O data, max. | 992 byte (max. 496 byte per direction) | ||||
Transmission rate | 100 Mbits/s, full-duplex | ||||
Dimensions in mm
1 | Installation on top hat rail TH 35-7.5 or TH 35-15 according to EN 60715 |
Dimensions in mm
1 | Installation on top hat rail TH 35-7.5 or TH 35-15 according to EN 60715 |
硬件和软件均可扩展(可伸缩、可远程配置、坚固耐用)
HNC100是Rexroth液压驱动控制的多用途控制器。丰富的接口与自由编程能力可满足不同要求,并能方便、灵活地集成到各种控制架构中。
应用始终简便。
Rexroth 是涵盖开环控制、闭环控制和驱动技术的液压系统专家。借助 WinPed7,可方便、快速地获得其专业技术支持。该软件工具提供强大的工程设计能力,帮助用户轻松、快速地实现应用。
开放兼容各种解决方案
对于液压驱动的控制方案,Rexroth 同样始终采用开放接口和编程标准。运动控制产品支持各种常用现场总线和以太网协议,能够无缝融入不同的自动化环境。
同级领先的液压控制器:
Rexroth 积累了液压与运动控制技术相互配合的独特经验,并据此优化了液压及混合驱动的控制策略,将其集成到可立即使用的软件中。